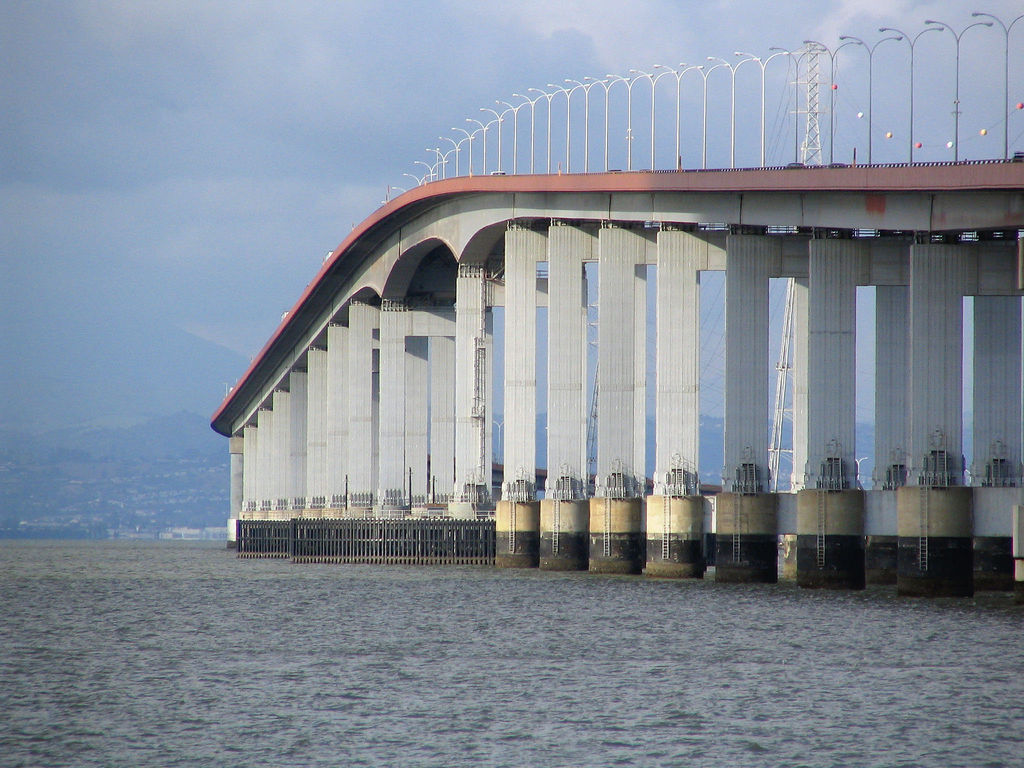
San Mateo Bridge, Highrise Section, San Francisco Bay Area
UC Berkeley Professor Ed Wilson raised a pointed concern about the Response Spectrum Method (RSM) that structural engineers should take seriously. In his 2015 note, he described the San Mateo Bridge retrofit as a revealing case study: RSM analysis indicated that numerous members required strengthening, but when time-history analyses were run using the actual ground motion records that generated the design spectra, the maximum demand-to-capacity ratios dropped by roughly a factor of three.
In seismic design, the demand-to-capacity ratio (DCR) is a fundamental metric for evaluating structural adequacy under earthquake loading. The demand represents the internal forces or deformations imposed on a structural element by the design seismic event — typically derived from a response spectrum analysis or nonlinear time-history analysis — while the capacity reflects the element’s ability to resist those effects without failure or unacceptable damage. A DCR less than or equal to 1.0 indicates that the element has sufficient strength or ductility to accommodate the seismic demand, whereas a DCR exceeding 1.0 signals overstress or exceedance of deformation limits, requiring redesign or retrofit.
In linear procedures, DCRs are computed from elastic force demands divided by expected member strengths, with acceptance criteria adjusted by modification factors (such as the m-factors in ASCE 41) that account for the ductility and deformation capacity of the element type. In nonlinear procedures, the ratio shifts toward deformation-based metrics — comparing inelastic rotation or drift demands against component deformation capacities defined at IO, LS, or CP performance levels. DCRs also inform the identification of weak stories, plan irregularities, and critical load paths, making them a practical diagnostic tool throughout both new design and existing building evaluation workflows.
The implication is significant — RSM’s modal combination rules, even with Complete Quadratic Combination (CQC), produce an envelope of peak values that cannot occur simultaneously in a real structure. For a retrofit program, that over-conservatism doesn’t just affect paper calculations; it drives steel, labor, and project cost. Wilson’s conclusion was that after more than 50 years, the RSM had outlived its justification and that time-history analysis should replace it as standard practice.
The case is compelling, but the transition raises its own challenges — and it’s worth asking whether supplemental intensity measures and testing methods could help bridge the gap, particularly for practitioners not yet equipped to run full nonlinear time-history workflows.
Five worth highlighting:
Pseudo Velocity Response Spectrum (PVRS) deserves more attention than it gets in structural practice. Unlike the standard acceleration response spectrum, the pseudo velocity representation plots on a four-coordinate (tripartite) log-log scale that simultaneously displays pseudo acceleration, pseudo velocity, and displacement as a function of frequency. This makes the energy content of a ground motion immediately readable across the full frequency range — stiff structures, flexible structures, and rigid-body behavior are all visible in a single plot. The PVRS also has a direct physical interpretation: pseudo velocity is proportional to the peak strain energy stored in the SDOF oscillator, making it a more meaningful descriptor of damage potential than spectral acceleration alone. The case for velocity-based spectra better characterizing structural demand for mid-period structures has only strengthened over time.
Input Energy Response Spectrum (IERS) is the natural next step from the PVRS, and it is the measure that most directly answers Wilson’s objection. The pseudo velocity spectrum reports the peak strain energy stored in the oscillator at one instant. The input energy spectrum reports how much energy the ground motion delivered to that oscillator over the entire record. Multiply the single-degree-of-freedom equation of motion by the relative velocity and integrate over the duration of the excitation:
$$ \int_0^t m \, \ddot{u} \, \dot{u} \, dt \; + \; \int_0^t c \, \dot{u}^2 \, dt \; + \; \int_0^t f_s(u) \, \dot{u} \, dt \; = \; – \int_0^t m \, \ddot{u}_g \, \dot{u} \, dt \; \equiv \; E_I $$
The three terms on the left are the kinetic energy, the energy dissipated by viscous damping, and the strain energy, where the strain energy divides into a recoverable elastic part and an irrecoverable hysteretic part $E_H$. The right side is the relative input energy. Housner introduced the idea in 1956; Uang and Bertero formalized the two competing definitions in 1990, distinguishing the relative input energy above from the absolute input energy obtained by integrating the total base shear through the ground displacement. The two definitions agree closely over the period range of practical engineering interest and diverge only at the extremes — the absolute form dominates for very stiff systems, the relative form for very flexible ones, where the mass essentially stands still while the ground moves beneath it.
Input energy is conventionally plotted not as energy but as an energy-equivalent velocity, so that it can be compared directly against the pseudo velocity spectrum on the same axes:
$$ V_E = \sqrt{ \frac{2 E_I}{m} } $$
Sweeping the oscillator natural period and repeating the integration produces the input energy response spectrum. The computational cost is modest — it is the same SDOF integration already required to build a response spectrum, with a few additional accumulators.
The partition of that energy matters as much as the total. Written per unit mass, the balance is
$$ E_I = E_K + E_D + E_A $$
where $E_K$ is kinetic energy, $E_D$ is the energy dissipated through damping, and $E_A$ is the energy absorbed as strain energy. For a linear oscillator the absorbed term is entirely recoverable; for a yielding structure it splits into elastic strain energy and irrecoverable hysteretic energy $E_H$. Hudson showed in 1956 that the absorbed term is simply the potential energy stored in the spring, $E_A = \frac{1}{2} K (x – y)^2$, which per unit mass reduces to
$$ E_A = \frac{1}{2} \omega^2 (x – y)^2 = \frac{1}{2} \left( \frac{S_v}{\omega} \right)^2 \omega^2 = \frac{1}{2} S_v^2 $$
where $S_v$ is the pseudo velocity from the response spectrum. That is the formal link between the first two measures on this list. The pseudo velocity spectrum is an absorbed energy spectrum in disguise — one half of its square is the peak strain energy per unit mass. What it omits is everything else in the balance: the kinetic term and, more importantly for damage, the dissipated term.
Two properties make it valuable. First, it is a cumulative quantity, so it responds to duration in a way that no peak-based spectrum can. Two records matched to the same design spectrum can differ by a factor of two or more in equivalent input velocity, and the structure feels that difference even though the RSM cannot see it. Second, and less obvious, the input energy is remarkably stable. It is governed largely by the mass, the period, and the ground motion itself, and is comparatively insensitive to the damping ratio and to the details of the hysteretic model. Peak displacement has no such property. That stability is what makes the spectrum useful as a screening tool: an elastic input energy spectrum remains a defensible estimate of the energy demand on an inelastic structure, so one computation per record serves a wide range of candidate designs.
The design use follows from the energy balance. Kinetic energy and elastic strain energy are recoverable and vanish once shaking stops. Viscous damping and hysteretic energy are not — and $E_H$ is the currency in which damage is actually paid. Published estimates place $E_H / E_I$ in the range of roughly 0.6 to 0.9 for yielding systems, increasing with ductility demand. Dividing the hysteretic energy demand by the energy absorbed per yield excursion gives an equivalent number of plastic cycles, which is exactly the quantity a Miner’s rule or Park-Ang damage assessment needs. The same output tells a designer how much energy a supplemental damping system or an isolation bearing has to absorb, which a force-based procedure never states explicitly. Akiyama’s energy-balance design method, long established in Japanese practice, is built on precisely this accounting.
This leads naturally to the next measure, because the two are members of the same family.
Arias Intensity (AI) captures what RSM entirely ignores: cumulative energy input. Defined as the time-integral of squared acceleration, AI reflects both amplitude and duration. Arias derived it as the total energy dissipated by a population of lightly damped oscillators distributed uniformly in frequency — which is to say, AI is the frequency-integrated collapse of what the input energy spectrum resolves period by period. The scalar is easier to tabulate; the spectrum tells you where in the frequency range the energy is going. Two ground motions can match the same design spectrum yet have very different Arias Intensities — and for structures with degrading stiffness or strength, that difference matters enormously. AI correlates well with cumulative damage, liquefaction potential, and permanent deformation. Used alongside RSM, it can flag cases where a long-duration record would drive significantly more damage than the spectral shape alone suggests — a practical trigger for requiring time-history follow-up, much as Wilson’s San Mateo analysis eventually required.
Fatigue Damage Spectrum (FDS) goes further still. Rather than characterizing the ground motion by a single peak response per frequency, FDS accumulates cycle counts across the response history using a rainflow-counting approach and applies a Miner’s rule damage model. The result is a frequency-dependent damage index that reflects both the number and amplitude of response cycles — something neither RSM nor a simple Arias Intensity scalar can provide. Where the input energy spectrum states how much energy arrived at a given period, the FDS states what that energy did to the material, weighting cycles by the fatigue exponent rather than by energy alone. FDS is well-established in mechanical shock and vibration testing (MIL-STD-810, IEST protocols), and its extension to seismic analysis of cycle-sensitive structural components — bolted connections, reinforced concrete members, base isolators — is a natural and underexplored direction.
Time Waveform Replication (TWR) brings the argument full circle to physical testing. Where Wilson advocates replacing RSM with time-history analysis in simulation, TWR does the equivalent on the shaker table: rather than driving a test article with a synthesized random or swept-sine signal shaped to match a target spectrum, TWR iteratively adjusts the drive signal until the table output replicates a target acceleration time history — typically a recorded earthquake ground motion or a simulation-derived base input. The result is that the test article experiences the actual temporal sequence of loading, including realistic phasing between frequency components, true peak-to-RMS ratios, and the cumulative cycle history that determines fatigue life. This is directly relevant to Wilson’s objection: an RSM-designed structure tested only to a shock response spectrum may never experience the correlated multi-cycle loading that a real earthquake imposes. TWR closes that gap experimentally. Combined with FDS and input energy verification — confirming that the replicated waveform delivers both the intended fatigue damage and the intended energy across the frequency range — TWR provides a physically rigorous complement to both simulation-based time-history analysis and the supplemental intensity measures described above.
There is an honest caveat on the input energy spectrum. Computing it requires the ground motion records, so it does not relieve anyone of the need to assemble a record suite. But that is a lower bar than it first appears — the San Mateo case turned on records that already existed, having generated the design spectra in the first place.
A note on computation. The second objection to energy spectra has always been cost. The traditional route is repeated time-domain integration of the SDOF response, once per natural frequency, with the energy terms accumulated along the way. For a short earthquake record that is nothing. For the long, non-stationary records that arise in mechanical shock and vibration work it becomes punishing — Sisemore, Harvie, and Skousen of Sandia National Laboratories reported a case that took roughly a month of computation, driven by the high sample rates needed to capture tooling vibration over signal durations measured in minutes or hours.
Their 2015 Shock and Vibration Symposium paper, Calculation of the Dissipated Energy Spectrum from a Fourier Amplitude Spectrum (SAND2015-8342C), removes most of that cost. The starting point is the result of Ordaz, Huerta, and Reinoso (2003), who showed that the input energy spectrum can be obtained directly from the Fourier amplitude spectrum of the base acceleration:
$$ \frac{E_I}{M} = – \frac{1}{\pi} \int_0^{\infty} |A(\omega)|^2 \, \Re \left[ H_V(\omega, \Omega, \zeta) \right] d\omega \qquad \text{with} \qquad H_V(\omega, \Omega, \zeta) = \frac{-i\omega}{\Omega^2 – \omega^2 + 2 i \zeta \omega \Omega} $$
Read that as a smoothing operation: the input energy spectrum is the squared Fourier amplitude spectrum smoothed by the real part of the oscillator velocity transfer function, with the oscillator natural frequency $\Omega$ as the sweep variable. The Sandia authors extended the idea to the dissipated energy. During the transient, substituting the spectral relation $\ddot{x}(t) = \omega \dot{z}(t)$ into the damping integral gives $E_D = 2 \zeta E_I$. The quantity of real interest, though, is the total energy dissipated once the system has come back to rest and the kinetic term has gone to zero, at which point the balance collapses to
$$ E_D = E_I – E_A $$
Both terms on the right already have frequency-domain forms — the Ordaz expression for $E_I$ and Hudson’s pseudo velocity identity for $E_A$ — so the dissipated energy spectrum comes essentially for free.
The verification cases are worth noting. Against the 18 May 1940 Imperial Valley record, both horizontal components, the Fourier and direct-integration results track closely, with the absorbed energy spectra effectively identical and small departures in the input and dissipated spectra at the extreme ends of the frequency range. On machining data the speedup was substantial: a ten-minute lathe cutting operation dropped from 41.7 minutes by direct integration to 12.6 minutes by the Fourier method, and a six-minute milling operation from 49.7 to 14.8 minutes, falling further to 7.62 minutes when the record — over 77 million points — was broken into roughly 1700 sub-records of $2^{16}$ points and the results combined. The overall gain was reported as a factor of three to six.
The milling case also carries a useful warning. The absorbed energy spectra agreed well, but the input and dissipated spectra did not, until the record was subdivided. The authors declined to declare either result correct, on the grounds that both are numerical approximations applied to an extremely long data set — a caution that applies equally to long-duration or high-sample-rate seismic records. One further limitation belongs in any structural application: the Fourier formulation is built on a linear oscillator, so what it delivers is the elastic energy demand. It does not replace nonlinear time-history analysis for partitioning $E_A$ into elastic and hysteretic components in a yielding structure. What it does is make the demand side cheap enough to compute for every record in a suite, which is exactly what a screening measure needs to be.
Taken together, that is the practical answer to the cost objection. Once the records are in hand, the spectra that characterize energy and duration cost almost nothing next to a nonlinear finite element time-history run. They are a screening step that identifies which records, and which structures, genuinely warrant the full analysis.
None of these replaces the response spectrum for establishing peak demand in design. But together they address Wilson’s core objection: RSM delivers an envelope of maximums with no information about energy content, duration, or cumulative damage capacity. A reasonable framework would use RSM for preliminary design and code compliance, PVRS to better characterize peak energy demand across the frequency range, the input energy spectrum to quantify how much energy the ground motion actually delivers and how much of it the structure must dissipate hysteretically, AI and FDS to identify duration- and fatigue-sensitive cases, TWR for physical qualification testing where realistic waveform fidelity matters, and full time-history analysis where supplemental measures signal that peak-only characterization is insufficient. That is a more targeted path to Wilson’s goal than retiring RSM all at once.
See also: An Alternative Method for Shock Testing
C. Sisemore, J. Harvie, and T. Skousen, Calculation of the Dissipated Energy Spectrum from a Fourier Amplitude Spectrum, SAND2015-8342C, Sandia National Laboratories, 86th Shock and Vibration Symposium, Orlando, FL, October 2015.
– Tom Irvine
📌 Related Bridge Dynamics Knowledge Hub
This case study is featured in our main Bridge Dynamics, Vibration & Structural Integrity Hub . Visit the hub to explore related articles on aeroelastic flutter, stress corrosion cracking, field modal testing, and seismic analysis.
📌 Related Earthquake Engineering Knowledge Hub
This article is featured in our main Earthquake Engineering & Structural Dynamics Hub . Visit the hub to explore related articles on shock response spectra, time history analysis, seismic equipment qualification, and structural case studies.
1 thought on “Seismic Time History & Response Spectrum Debate”